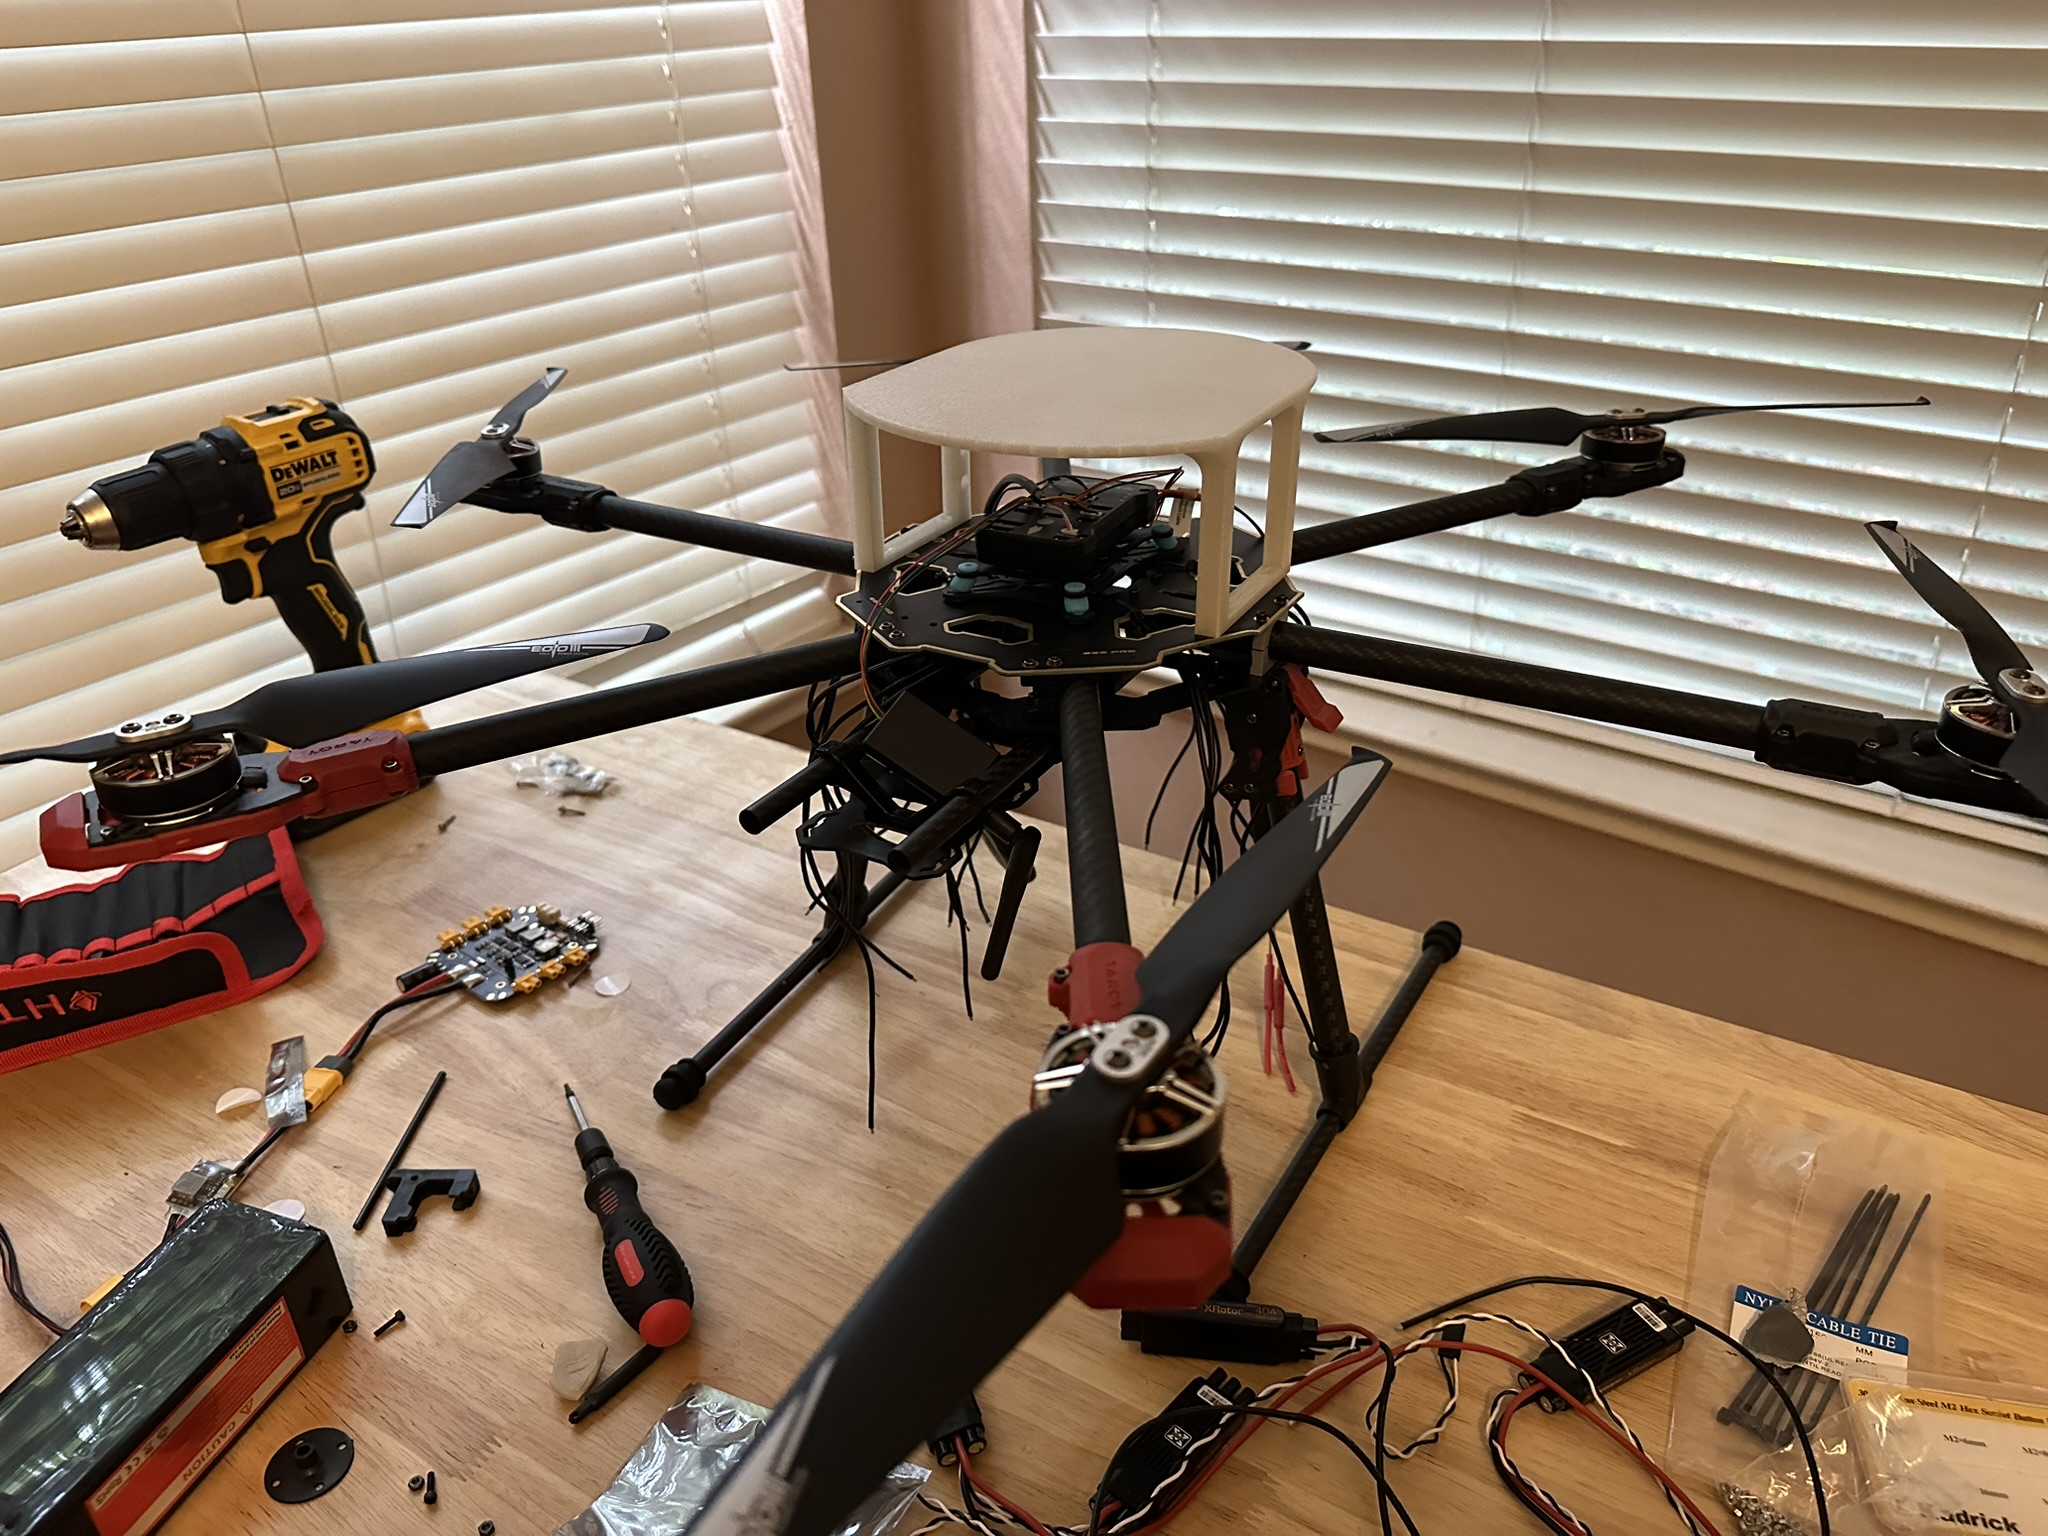
This project is still a work in progress. After successful manual flight testing, the aircraft suffered a crash that paused this iteration. I plan to revisit the build in the future, rebuild the platform, and continue experimenting with onboard vision and autonomy.
Ongoing · Future rebuild plannedBuilding a large hexacopter around onboard vision hardware.
I built this 680 mm carbon-fiber hexacopter as a platform for experimenting with onboard computing and computer vision. The aircraft combined a Pixhawk 6 flight controller with an NVIDIA Jetson Orin Nano and an Intel RealSense depth camera.
The mechanical and electrical integration required mounting the flight hardware, routing power and signal wiring, packaging the battery and onboard computer, and developing custom 3D-printed mounts for the added hardware.
The aircraft was successfully flown manually. I also experimented with Python and OpenCV on the Jetson for computer-vision and autonomy work, but I did not reach a working autonomous-flight implementation before the aircraft suffered a crash. The project is therefore unfinished rather than complete, and I plan to return to it in a future rebuild.
What I worked on
- Assembled and integrated the 680 mm carbon-fiber hexacopter platform.
- Integrated the Pixhawk 6 flight controller and supporting electronics.
- Added an NVIDIA Jetson Orin Nano for onboard computing.
- Integrated an Intel RealSense depth camera and custom mounting hardware.
- Experimented with Python and OpenCV for onboard computer vision.
- Completed successful manual flight testing before a crash paused the project and ended this iteration.
Future work
I plan to revisit the project with a rebuilt airframe, refine the onboard hardware integration, and continue the Jetson/RealSense computer-vision work. The next iteration will build on what I learned from the first flight-capable version and the crash that ended it.